Key Takeaways
- E-axle integration removes the standalone traction motor from the test plan, and PMSM emulation at power gives the production inverter a machine to work against while prototypes are scarce.
- The machine model sets the value of the bench, because saturation, cross-coupling and harmonics decide how current loops and torque tables behave at peak load.
- Emulation covers the electrical interaction at the phase terminals, so mechanical, thermal and acoustic questions still need integrated hardware and a planned correlation step.
PMSM emulation lets you mature e-axle inverter controls on the production inverter months before an integrated drive unit exists.
An e-axle packs the motor, inverter and gearbox into one housing, so the free-standing machine your controls team used to test against disappears from the program plan. That gap is growing with volume. Global electric car sales exceeded 17 million in 2024, and every new platform behind that figure needs an inverter calibrated to a specific traction motor on a fixed launch date.
Motor emulation at power closes the gap, but only as far as the machine model is faithful. A bench that reproduces saturation, cross-coupling and harmonics of your PMSM motor teaches the inverter the machine it will ship with. A bench running a textbook model teaches it a different one, and you’ll pay for the difference during integration.
What an e-axle changes for inverter test access
An e-axle is an electric drive unit that integrates the traction motor, the inverter and a reduction gearbox in one housing, usually with shared cooling and internal busbars. That integration removes the standalone motor, the phase cables and the exposed shaft that inverter teams have always relied on for testing.
Packaging targets explain why the parts merged. Reaching the 33 kW/L for a 100 kW traction drive system that the United States Department of Energy targeted for 2025 leaves no room for separate enclosures or cable runs. Phase connections become short busbars inside the casting. The rotor position sensor sits behind a cover, and the only mechanical output is the gearbox flange.
The practical result is a queue. Integrated prototypes arrive late, there are only a few of them, and mechanical, thermal and noise teams all need the same units. Your inverter hardware and firmware are often ready a full sample phase earlier, with nothing representative to connect to.
How PMSM emulation stands in for the traction motor
PMSM emulation replaces the machine with a power electronic emulator that connects to the inverter’s phase terminals and draws the currents the motor would draw. A real-time machine model running on an FPGA calculates those currents from the voltages the inverter applies, so the production power stage, gate drivers and firmware all operate at full voltage and current.
Picture the inverter commanding peak torque at mid speed. The emulator measures the three switched phase voltages, solves the machine equations within a fraction of a switching period, and regulates its own converter so the current through the coupling inductors matches the model. Emulated resolver or encoder signals return rotor position to the controller. Power circulates through the DC link, which means the supply only covers losses, and the inverter can’t tell that no rotor is turning.
What a PMSM model needs to represent for inverter testing
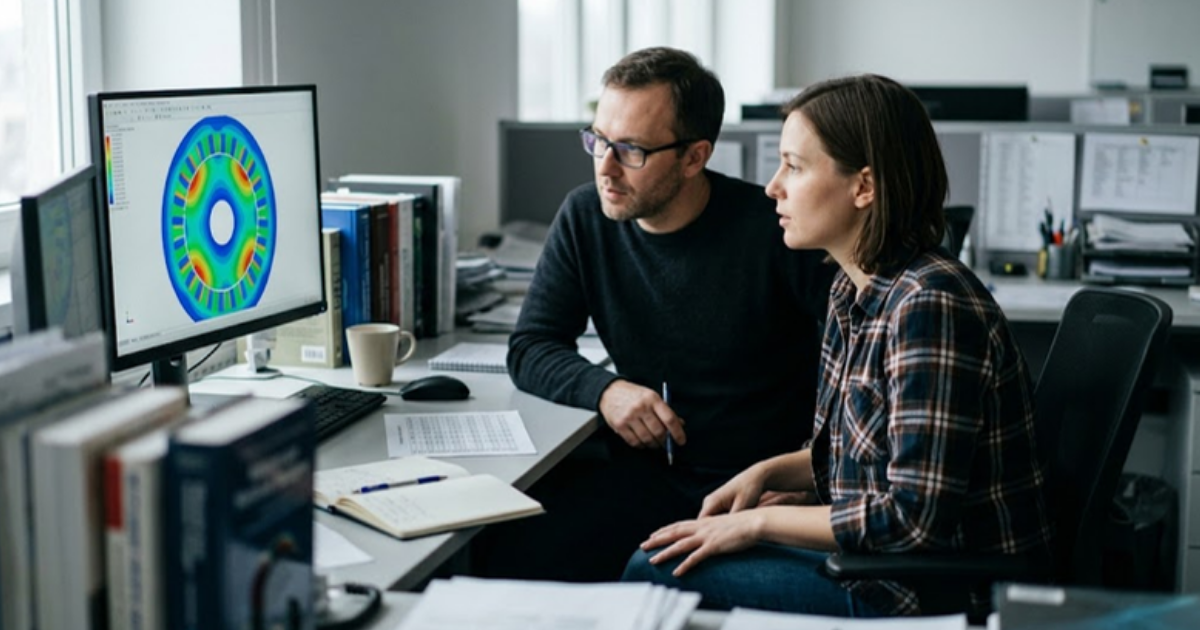
A PMSM model for inverter testing needs to represent how flux linkage changes with current and rotor angle across the whole operating range. Nameplate inductances and a single magnet flux value describe one operating point. Your inverter will spend its life at all the others.
Interior permanent magnet machines make this unavoidable. They produce a large share of their torque from reluctance, which depends on the gap between the d-axis and q-axis inductances, and both inductances fall as the iron saturates. Current on one axis also shifts flux on the other. A model with fixed values misses both effects exactly where the inverter works hardest.
The fix is to use the motor designer’s own data. Finite element analysis already produces flux linkage and torque tables indexed by d-axis current, q-axis current and rotor angle. An FPGA model that interpolates those tables reproduces saturation, cross-coupling, torque ripple and distorted back-EMF without anyone hand-fitting parameters.
Ask for those tables as soon as the electromagnetic design freezes. Each effect they capture maps to a specific inverter behaviour you’d otherwise meet for the first time on integrated hardware.
| Machine effect in the model | What it shapes on the inverter side |
| Magnetic saturation of both axes | Current loop gain shifts with load, so tuning that is stable at light torque can ring at peak current. |
| Cross-coupling between the axes | Decoupling terms in the controller miss their target and torque accuracy drifts at high current. |
| Spatial harmonics from slots and magnets | Phase currents carry ripple that tests harmonic compensation and DC link capacitor stress. |
| Winding and magnet temperature | Resistance and magnet flux move with heat, which changes torque per amp and voltage headroom. |
| Position sensor offset and delay | Angle error rotates the current vector and shows up as lost torque or instability at high speed. |
Why constant parameter machine models mislead inverter control tuning
Constant parameter machine models mislead control tuning because current loop gains, decoupling terms and torque lookup tables are all calculated from inductances that move under load.
“Tuning against fixed values produces a controller that is correct for a machine that doesn’t exist, and the error grows with torque.”
Consider a generic machine whose q-axis inductance drops by 40% between light load and peak current. You set the proportional gain for a 1 kHz current loop bandwidth using the unsaturated inductance. At peak current, the same gain acts on 60% of the inductance, so the loop bandwidth rises to roughly 1.7 kHz. Add the computation and sampling delay of a 10 kHz controller, and the phase margin you measured at light load is largely gone.
On a bench with a fixed-parameter model, that controller looks perfect. With a flux-mapped model, the oscillation appears on the first torque sweep, and you fix it with gain scheduling in an afternoon. The same logic applies to field-oriented control tables for maximum torque per amp, which sit in the wrong place if the model’s reluctance torque is wrong.
Which inverter tests you can run without the physical motor
You can validate current control, torque accuracy, field weakening, protection and fault response at full power without the physical motor. These tests depend on the electrical interaction between the inverter and the machine, and a faithful emulated PMSM reproduces that interaction at the phase terminals across the full speed and torque map.
High speed is a good illustration. A generic machine with 4 pole pairs spinning at 16,000 rpm has an electrical frequency near 1,067 Hz. A 10 kHz controller then gets fewer than 10 switching periods per electrical cycle, which is where delay compensation and overmodulation strategies succeed or fail. The emulator reaches that operating point in milliseconds, with no gearbox and no overspeed risk.
Five test groups move onto the emulation bench once the model is trusted.
- Current loop tuning and gain scheduling across the torque range
- Torque accuracy and efficiency mapping over the speed range
- Field weakening and voltage limit operation at top speed
- Sensor faults such as resolver loss or angle offset
- Electrical faults such as an open phase or active short circuit
Repeatable fault injection is where the schedule benefit is easiest to see. Triggering an active short circuit at top speed on a scarce prototype risks demagnetizing it. The FPGA Electric Machine Library from OPAL-RT provides PMSM models that an emulation bench runs at power, so you repeat that fault as often as the safety case needs.
Where emulation stops short of the integrated e-axle
Emulation stops at the electrical terminals. It doesn’t reproduce gear mesh loads, shared oil or coolant circuits, bearing currents, shaft torsion or the acoustic signature of the assembled unit. Those interactions only exist inside the housing, and they still need time on integrated hardware and a load machine.
The model also carries the limits of its source data. Finite element tables describe the design intent, and built machines differ through magnet tolerance, lamination processing and assembly. Plan a short correlation step when the first unit arrives. Compare measured back-EMF and phase current waveforms at a handful of operating points against the emulated ones, update the tables, and you’ll know how far to trust everything the bench told you earlier.
Model fidelity decides how much the inverter learns before integration
“Model fidelity sets the value of every hour your inverter spends on an emulation bench.”
A flux-mapped PMSM gives the production controller the same nonlinear machine it will meet inside the e-axle, so the calibration carries over. A simplified model fills the calendar with tests that have to be repeated.
Teams that get this right treat the machine model as a deliverable with an owner. Someone requests the finite element tables, checks them against the first back-EMF measurement, and keeps a version history alongside the inverter firmware. It isn’t glamorous work. It’s the difference between an integration phase spent confirming results and one spent rediscovering the motor.
That discipline is what we build for at OPAL-RT. Emulation earns its place in an e-axle program when the inverter on the bench faces the traction motor it will ship with, at power, long before the casting is closed.
Power Electronics
10 / 15 / 2026
Flying capacitor converter simulation for multilevel designs
How a flying capacitor converter balances its capacitor voltages through switching, where that balance breaks, and what a switching-accurate simulation has to capture.
Industry applications
10 / 12 / 2026
Validating eVTOL electric propulsion before the first flight article
A walk through motor, inverter and battery validation for eVTOL aircraft and the points where real-time simulation carries propulsion evidence ahead of flight test.
Power Electronics
10 / 11 / 2026
Totem pole PFC design and real time validation
How a totem pole PFC works, why its control is hardest at the AC zero crossing, and how real-time testing checks that transition before hardware is built.